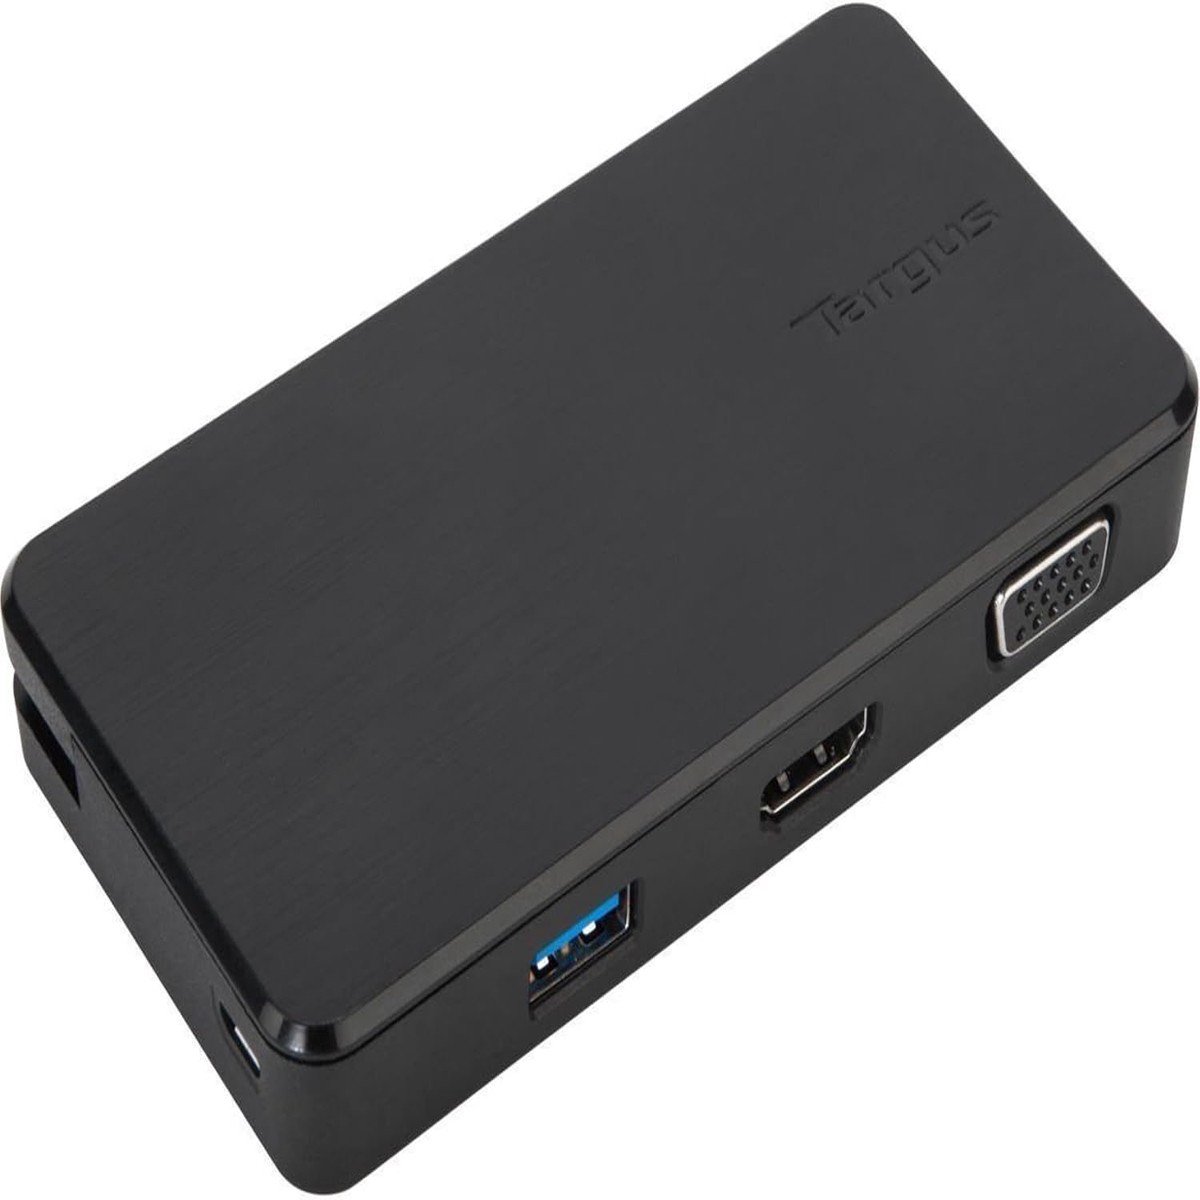
Targus DisplayLink USB 3.0 & USB-C Dual Travel Dock | HDMI VGA Gigabit Ethernet | Clearance Sale
$79.00$39.50

The MPU-6050 is the latest product of invensense company products. This sensor is used in Ardupilot autopilot. The sensor contains a 3 axis MEMS accelerometer and a 3 axis MEMS gyro in a single chip. It is very accurate, since it contains 16-bits analog to digital conversion hardware for each channel. Therefore it captures the x, y, and z channel at the same time.
Also, it is accurate because you have the 3 axis gyro and 3 axis accelerometers on single chip so you do not need to align them.
The sensor has a "Digital Motion Processor" (DMP), also called a "Digital Motion Processing Unit". This DMP can be programmed with firmware made by invensense and is able to do complex calculations with the sensor values.
Features
MPU-6050 Arduino code and libraries for raw data
MPU-6050 Arduino code and libraries using build in DMP processor (Euler & Quaternions)
MPU-6050 Arduino code and libraries using Kalman Filter
The MPU-6050 is the latest product of invensense company products. This sensor is used in Ardupilot autopilot. The sensor contains a 3 axis MEMS accelerometer and a 3 axis MEMS gyro in a single chip. It is very accurate, since it contains 16-bits analog to digital conversion hardware for each channel. Therefore it captures the x, y, and z channel at the same time.
Also, it is accurate because you have the 3 axis gyro and 3 axis accelerometers on single chip so you do not need to align them.
The sensor has a “Digital Motion Processor” (DMP), also called a “Digital Motion Processing Unit”. This DMP can be programmed with firmware made by invensense and is able to do complex calculations with the sensor values.
Features
MPU-6050 Arduino code and libraries for raw data
MPU-6050 Arduino code and libraries using build in DMP processor (Euler & Quaternions)
MPU-6050 Arduino code and libraries using Kalman Filter
There are no reviews yet. Be the first to review this product!
Add a review
Your email address will not be published. Required fields are marked *